Showing posts with label Drawings. Show all posts
Sunday, September 25, 2011
Tuesday, August 2, 2011
Tuesday, May 3, 2011
Friday, March 18, 2011
New calculations for positioning
Update : 06:01, 18.03.201, I am almost done with the C code on Arduino ... Too sleepy, going back home now ...
I should write a program that can simulate the workspace as I have no idea what are the valid points on workspace that are reachable by the feet.
----------------------
New calculations for positioning, the whole thing could not be easier than this ...
Wednesday, November 17, 2010
Climbing robot, brain storming
This project is an ongoing rapid prototype which is under development by Puya Afsharian & me …
Requirements :
Components :
Magnet #1
Magnet #2
Magnet #3
Magnet #2
Magnet #3
Motor #1-1
Motor #1-2
Motor #2-1
Motor #2-2
Motor #1-2
Motor #2-1
Motor #2-2
Algorithm & states :
- Initial state :
Mag. 1,2,3 -> ON
Motor 11,12,21,22 -> OFF - Lift state :
Mag3 -> OFF
Mag 1,2 -> ON
Motor 12, 22 -> CCW ON
Mag3 -> ON - Move Up Right state :
Mag2 -> OFF
Motor 11 CW ON MAX
Motor 12 CW ON -> Vertical(Parallel with chassis)
Mag 2 -> ON - Move Up Left state :
Mag1 -> OFF
Motor 21 CW ON MAX
Motor 12 CW ON -> Vertical(Parallel with chassis)
Mag 1 -> ON
and again to Lift state
Sunday, September 5, 2010
New foot design details
I have received these along with the foot from my supervisor Mats Høvin.
Actuator Design
Encoders mounted on Motor jacket
Arudino + Motor drivers
Encoder
Source of all details is www.robotikk.com
Thursday, July 15, 2010
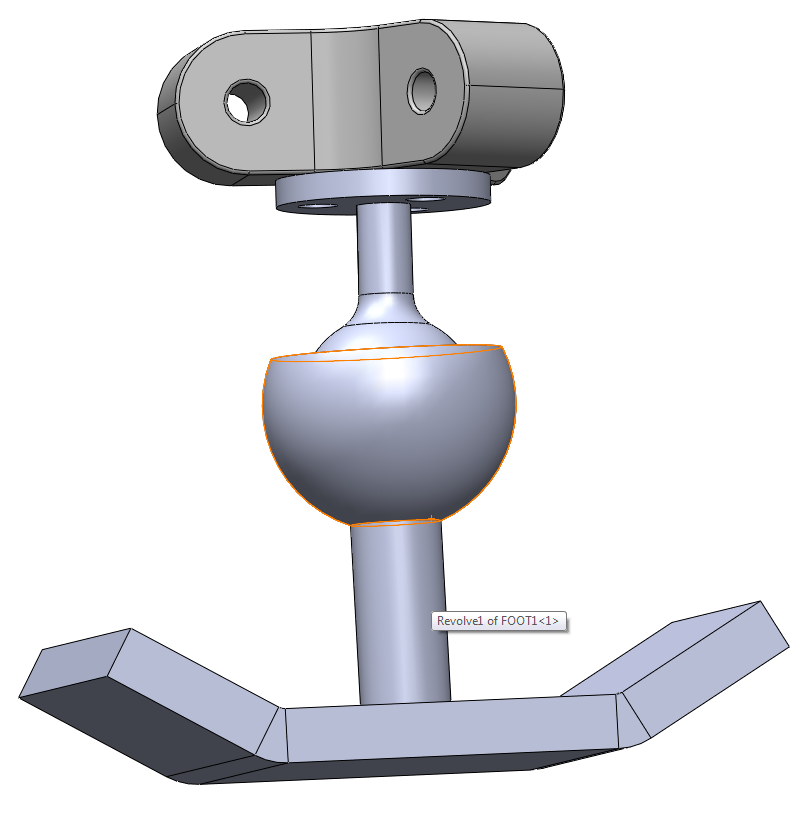
New feet design for walloid
As explained in the previous post, I received new robot design which is under development by Mats Høvin a while ago. While working on a summer-project which is highly related to my master thesis & receiving some tips discussing the new design with some friends*, I came up with some new ideas regarding climbing solutions.
My idea is a very simple grip for each foot which gives the climbing robot the ability to hang on a nail(bolt) on the wall. The curved(bent) part in the middle will be where the robot would grip the nail. I am thinking of using a flex sensor there to receive a signal every time a foot is hanging to a bolt. Meaning if we want to make a move at a time, before moving the foot, we should receive 4 bent resistor signals from the robot feet and while moving, all the way we should be receiving 3 bent resistor signals from other three remaining hanging feet.When we are finished with moving our foot to the new point of griping, we should again receive the 4th signal again ... I am still working on this idea and going to discus it as soon as my supervisor is back from his holiday.
*Thanks to my colleague Tarjei & my friend Magnus :-)
For more snapshots click read more ...
Labels:
Climbing Solutions,
Drawings,
Plans,
Video,
Walloid
Tuesday, July 13, 2010
New design received from Mats
I have received new robot design, plus new motor designs from Mats Høvin(my supervisor). Right now I am working on two things at the same time. One is the new motor design which is used in this chassis and at the same time I am working on Mats design to develop a grip(feet) for this chassis. I have came up with some ideas that will soon be posted here ...
Down here you see the Mats Høvin chassis for the climbing robot :
New chassis designed by Mats
New Motor designed by Mats
New Motor chassis designed by Mats, printed in 3D printer
Wednesday, May 5, 2010
Thursday, April 29, 2010
Monday, April 26, 2010
Possible electronic solution, walloid
The whole idea is based on java program being able to steer the motors through Adruino cards. The java program would be run on an Linux OS on an Eee motherboard. As we have 12 motors for controlling the robot, we would be needing a USB hub with 12 outputs.
Thursday, April 15, 2010
Early Design, Walloid
The hardware design(X2 Module) designed by my supervisor Mats Høvin. I have to start designing the end effector which will contain the solution for climbing.
Source : robotikk.com
Thursday, April 1, 2010
Some wild ideas about climbing feet
Some early wild drawings about how the climbing feet should look like, in case of using ring bolts …
Subscribe to:
Posts (Atom)


